Pulley Finger
A biomimetic robotic finger driven by Dyneema tendons, TPU ligaments and servos.
- Year
- 2023
- Context
- Robotics engineering intern at Kind Humanoid
- Timeline
- Three weeks
- Discipline
- Robotics, Biomimetics
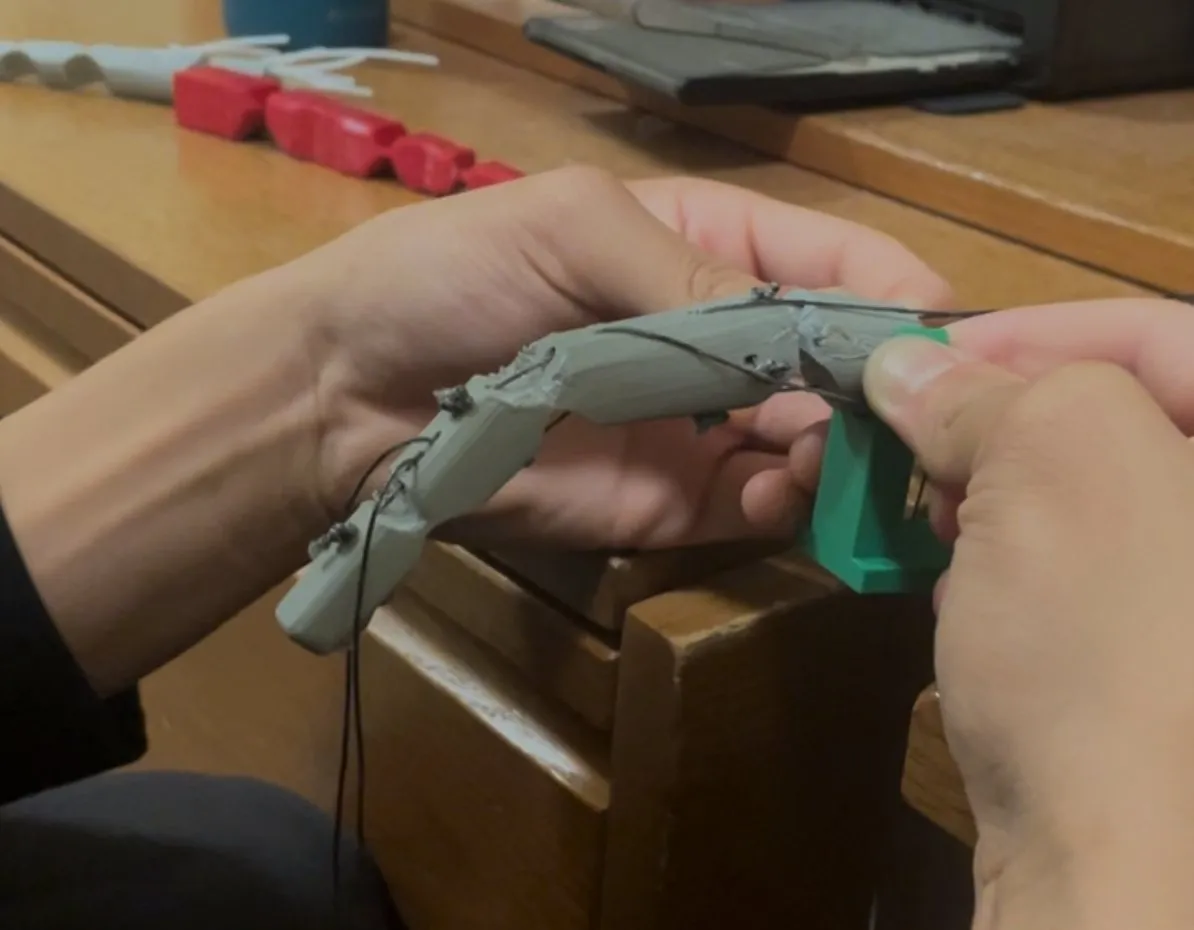
My first biomimetic robotic finger, designed and developed as a robotics engineering intern at Kind Humanoid.
The build
01
Tendons and ligaments
The design copies the anatomy of a human finger. Servos drive it through artificial tendons made of Dyneema, with ligaments made of TPU.
02
Custom pulleys
I wrote Python scripts to integrate the servo actuators with a custom pulley design built into the finger.
03
Fast iteration
Using CAD and 3D printing, I prototyped through multiple designs within a three-week timeline.